01
10-Axis Coordinated Motion
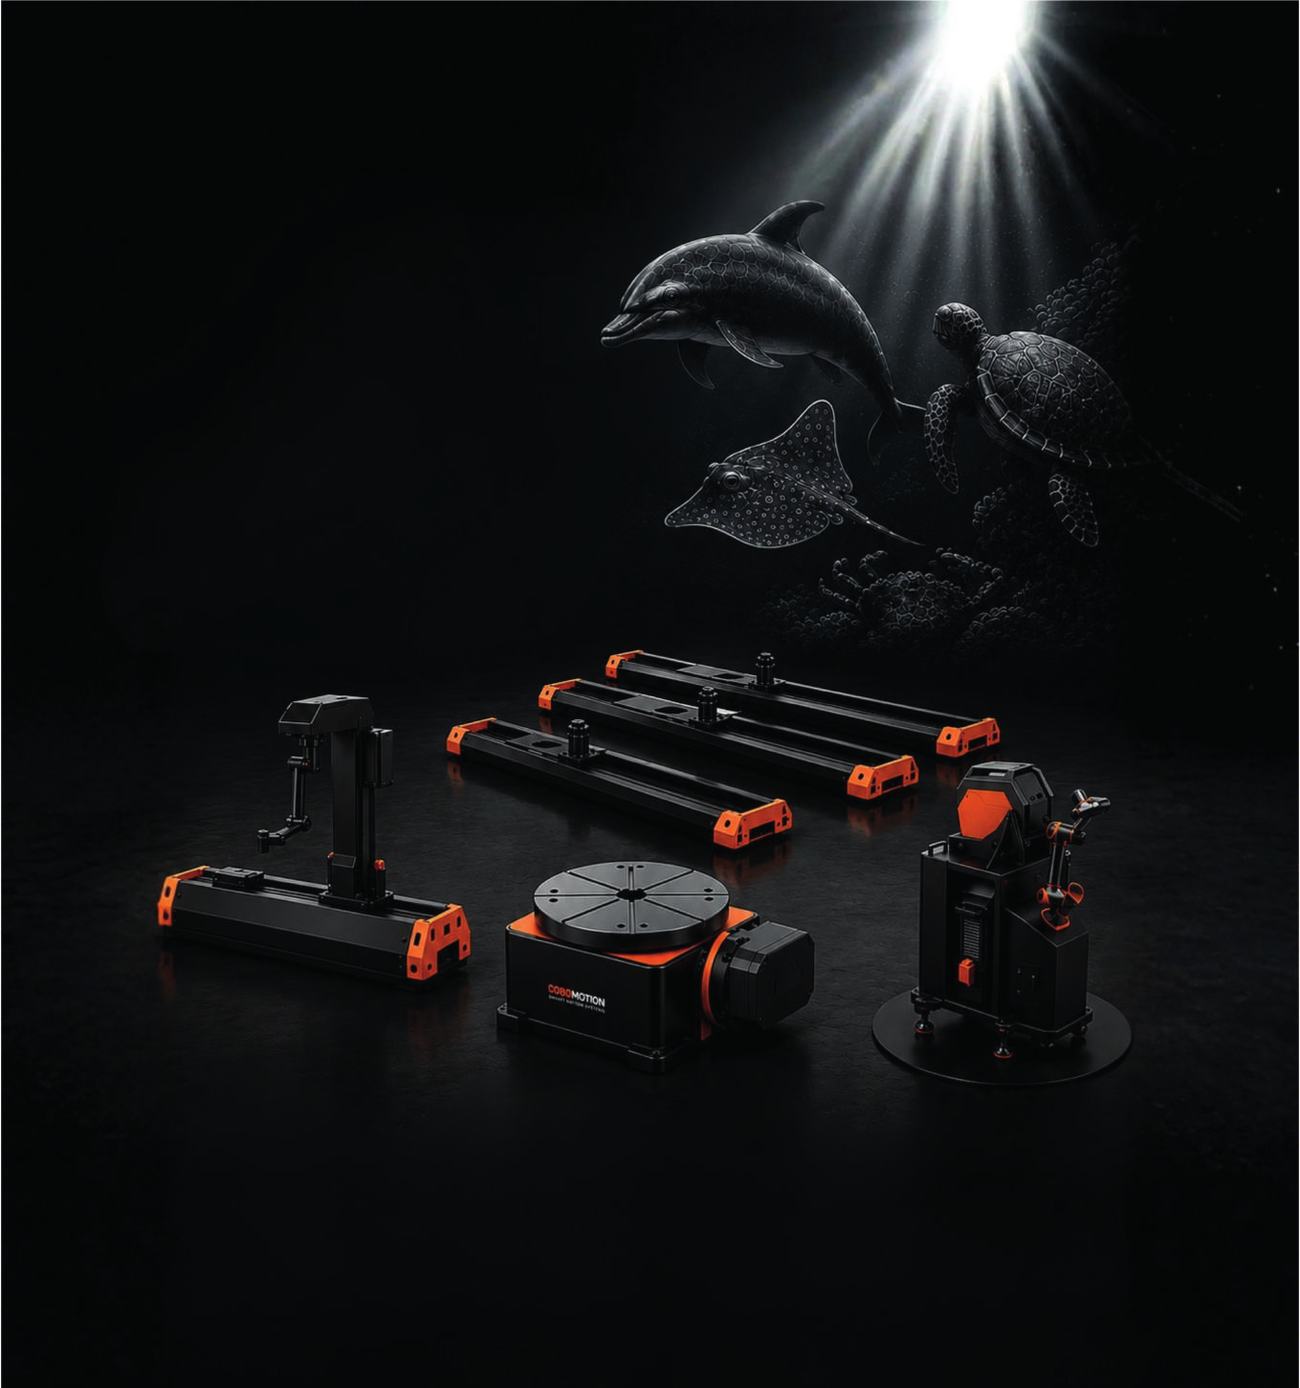
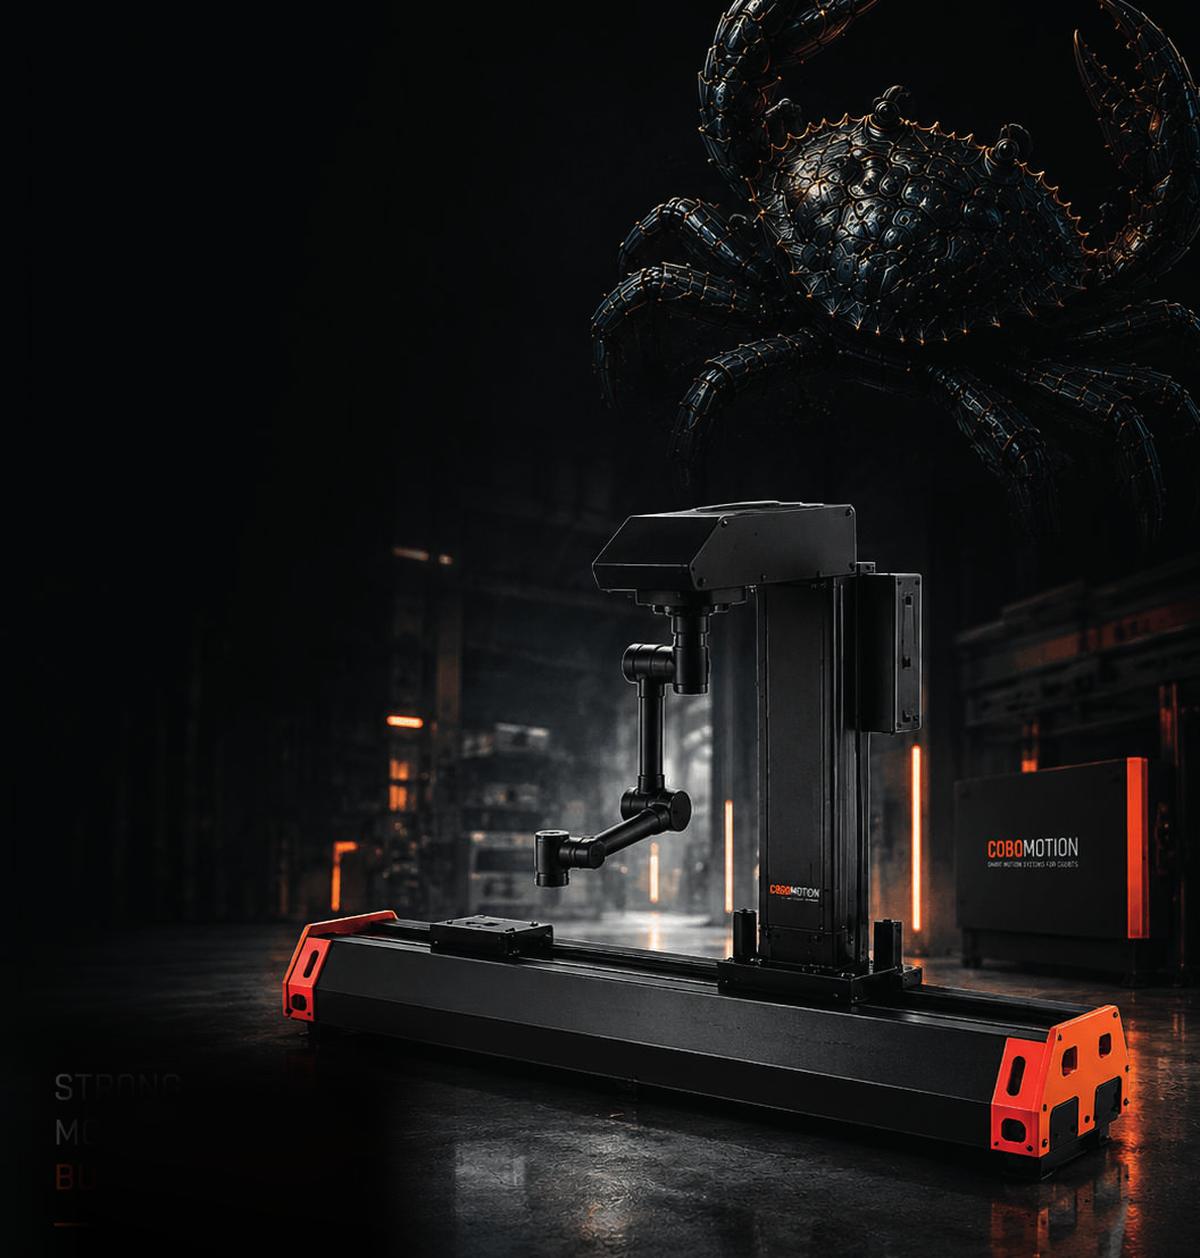
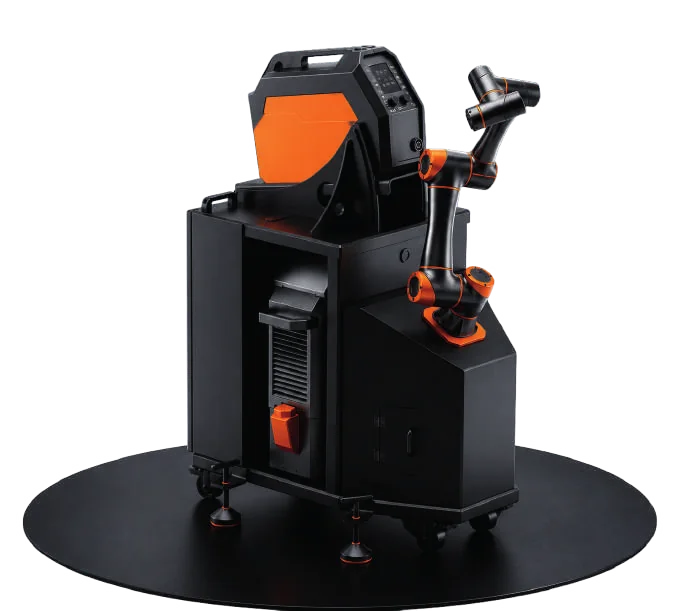
The 6 axes of the collaborative robot and the X-Y-Z-R external axes of the COBOMOTION Pillar are controlled as one integrated 10-axis robotic system. Instead of only repositioning the robot, SI-CWPS evaluates the complete kinematic structure — robot reach, torch orientation, working distance, joint limits, collision risks, accessibility and weld geometry — to calculate the optimum combination of robot and external-axis movements for larger, more complex workpieces.